


‹
›
October 2026 – Present
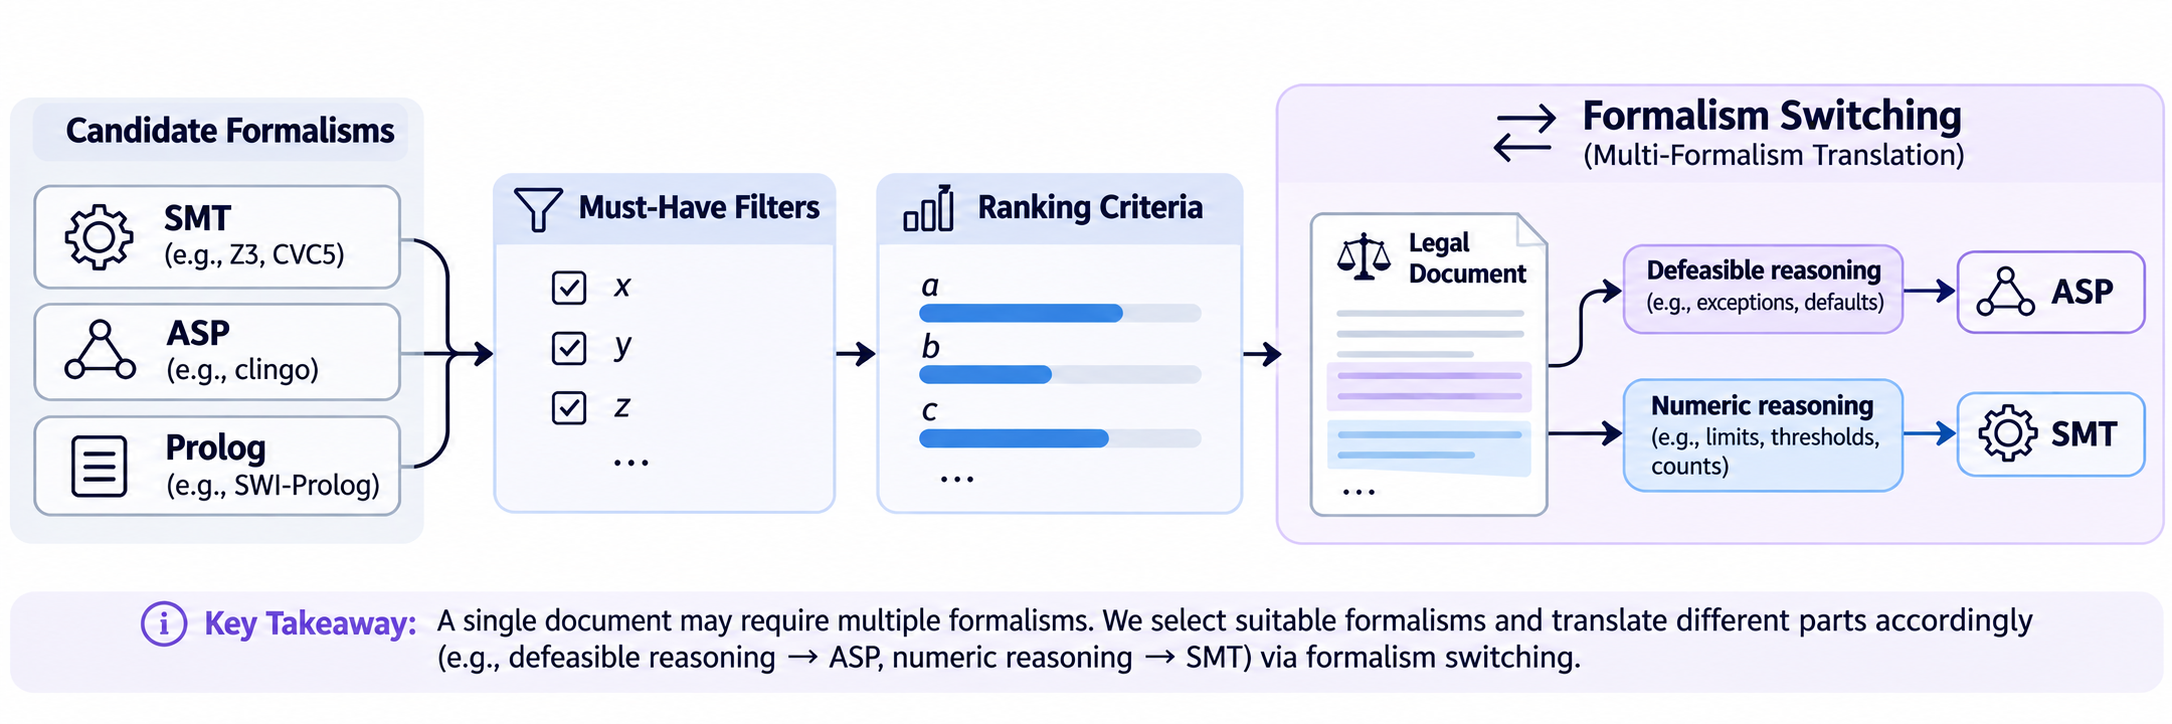
We systematically survey the literature and conduct expert studies to create a mechanistic, two-tier rubric for selecting the most appropriate formal language for a given problem, based on must-have properties and good-to-have rankings.
October 2026 – Present
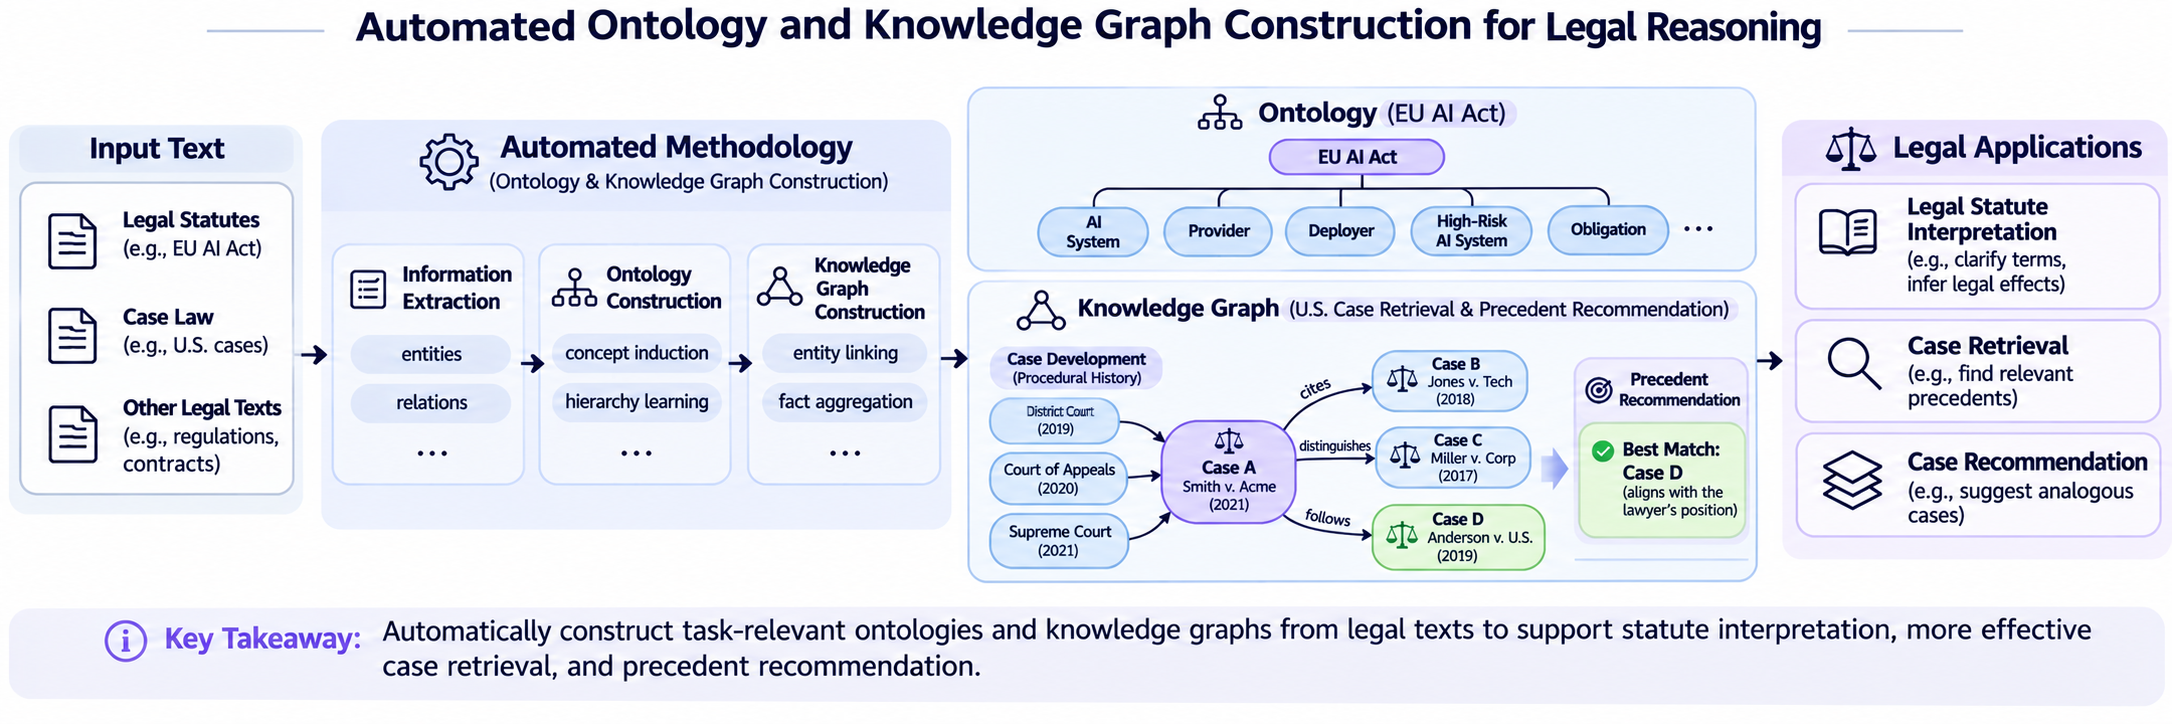
We are designing an automated methodology to construct ontologies and knowledge graphs from text, supporting applications such as legal statute interpretation, improved case retrieval, and recommendations.
September 2026 – Present
Exploring neuro-symbolic approaches to understanding and answering questions about long-form videos.
March 2026 – Present
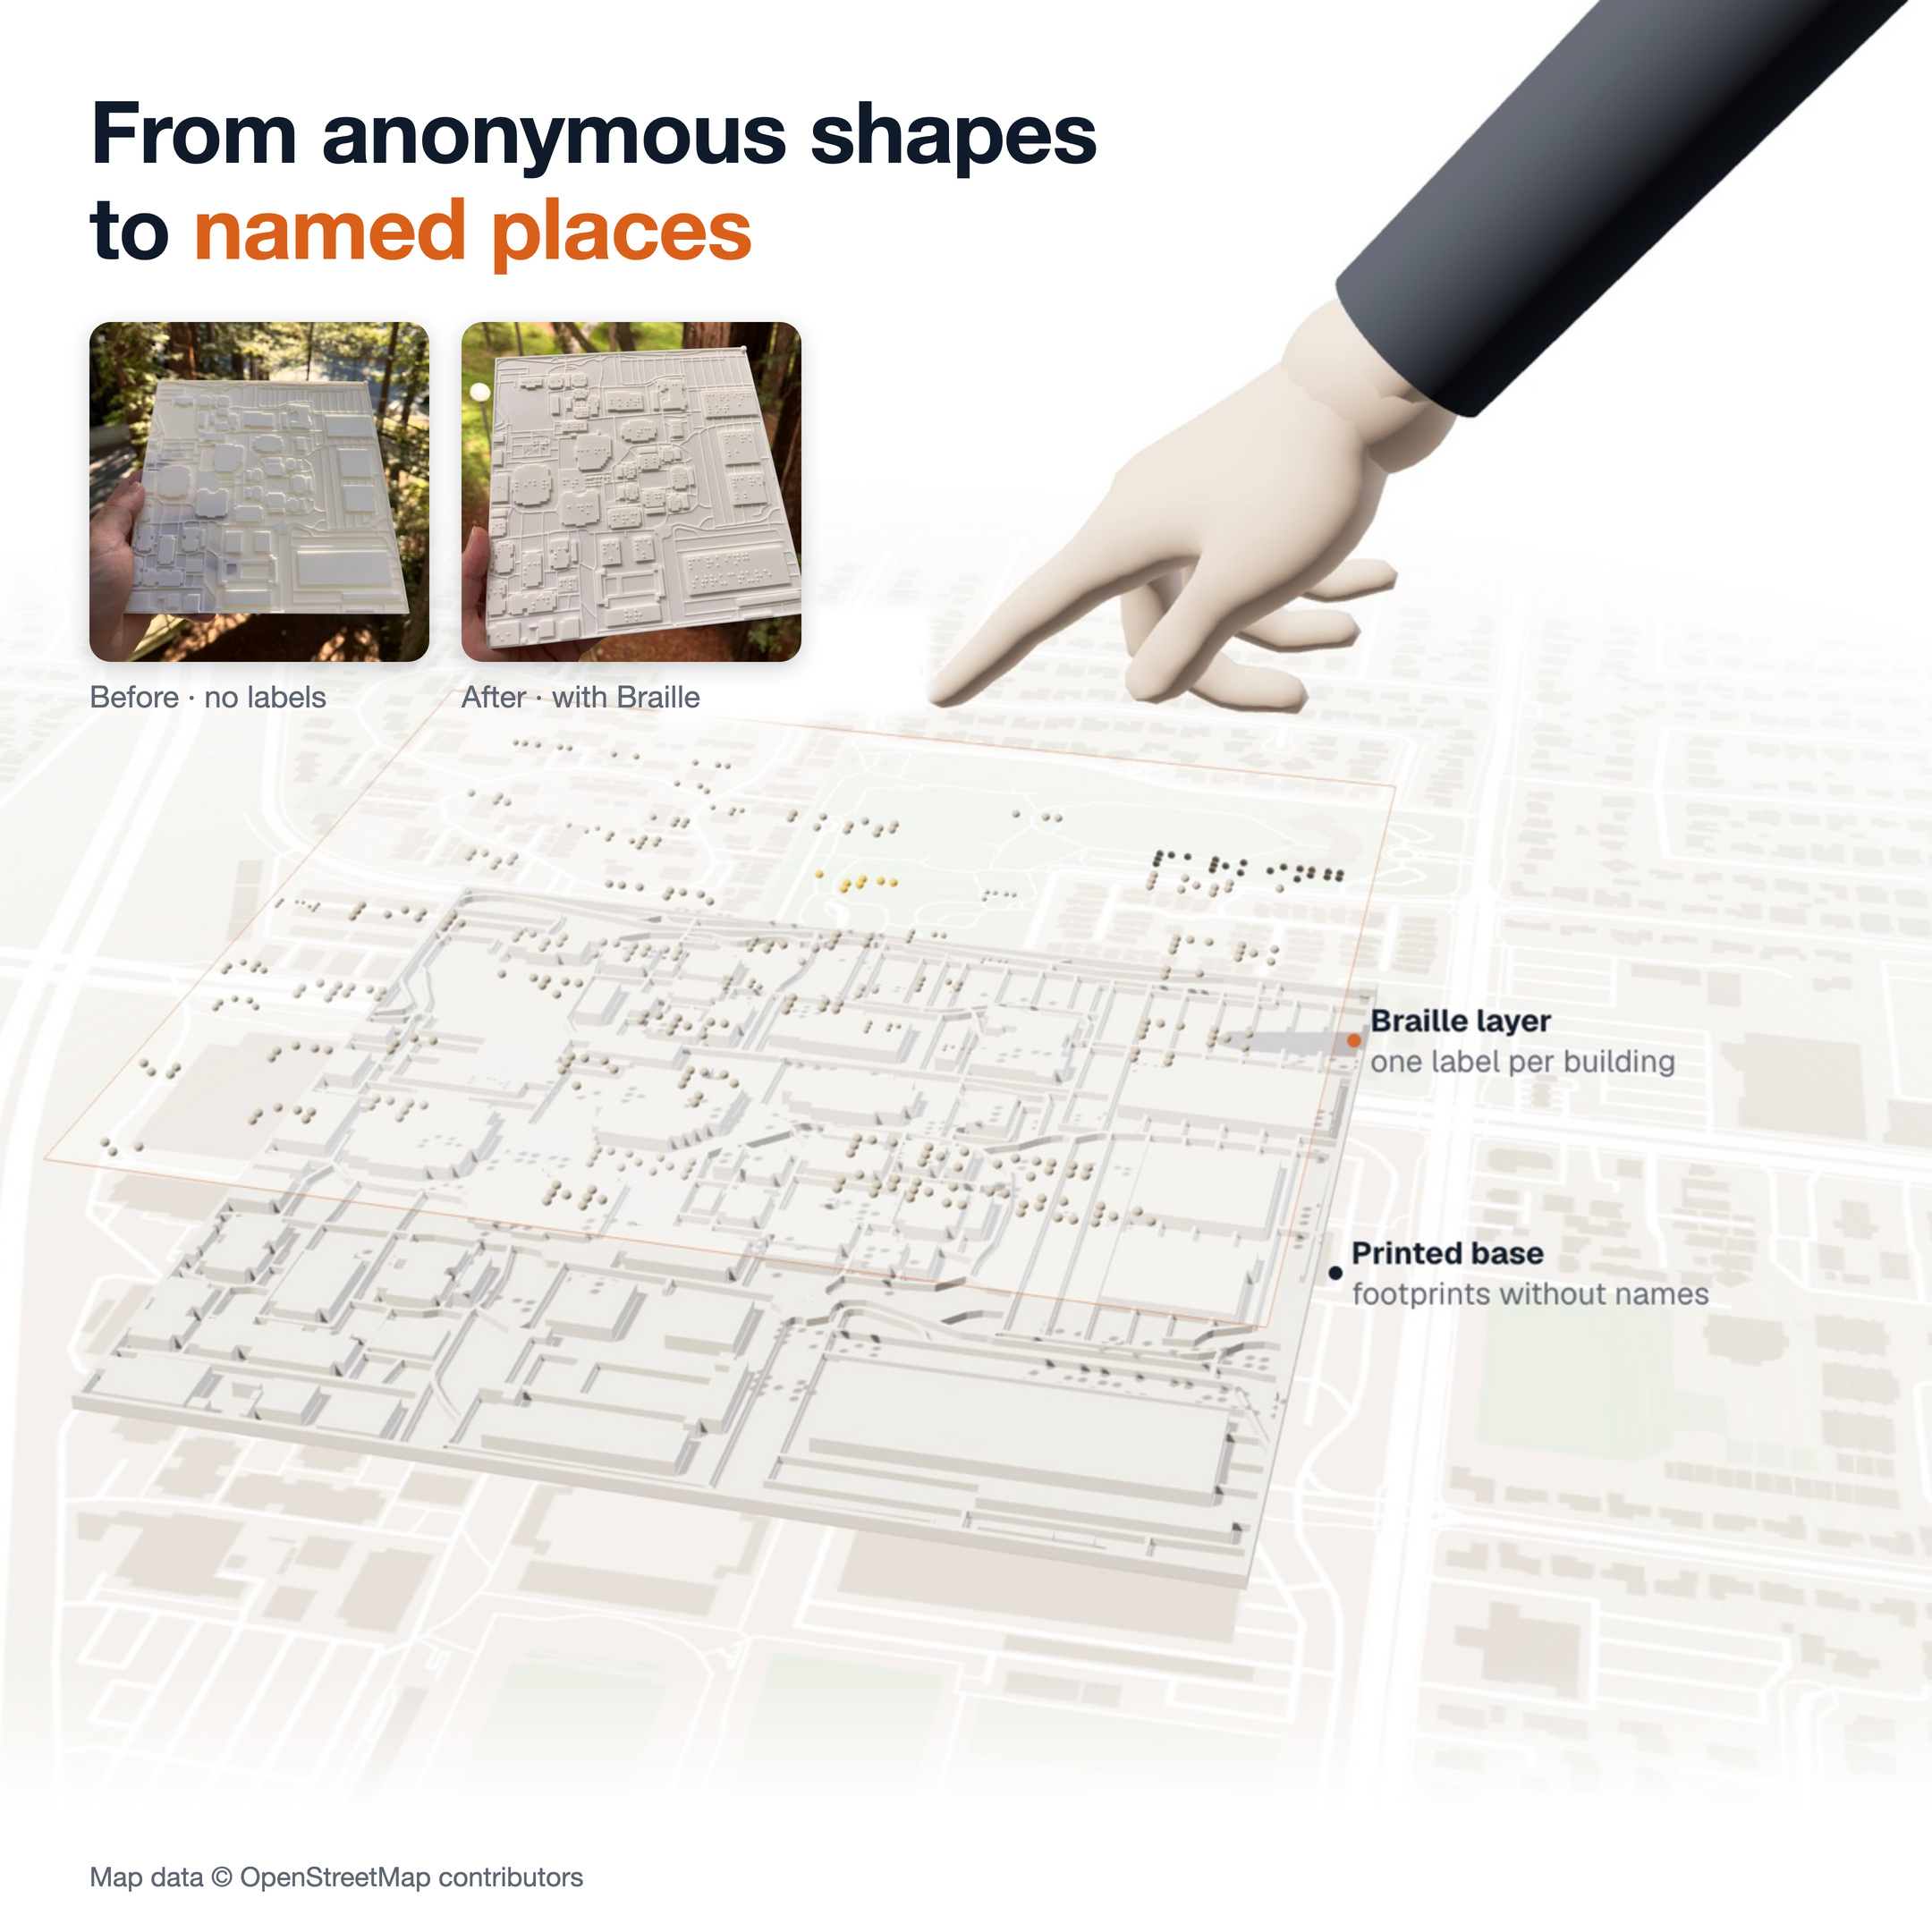
Tactile Map Annotation: On a tactile map, a building under the finger is an unnamed shape. Our tool gives it a name in Braille. Ten blind and low-vision readers compared labeled and unlabeled prints. By linking the 3D model with a real-world map, annotation becomes easy and sharable across map modalities and places.
January 2026 – Present
SLuG - Schema Logical Guidance is a project that tries to understand current LLMs/VLMs’ ability to provide reliable guidance when visual input is insufficient to answer an image-based question.
December 2025 – Present
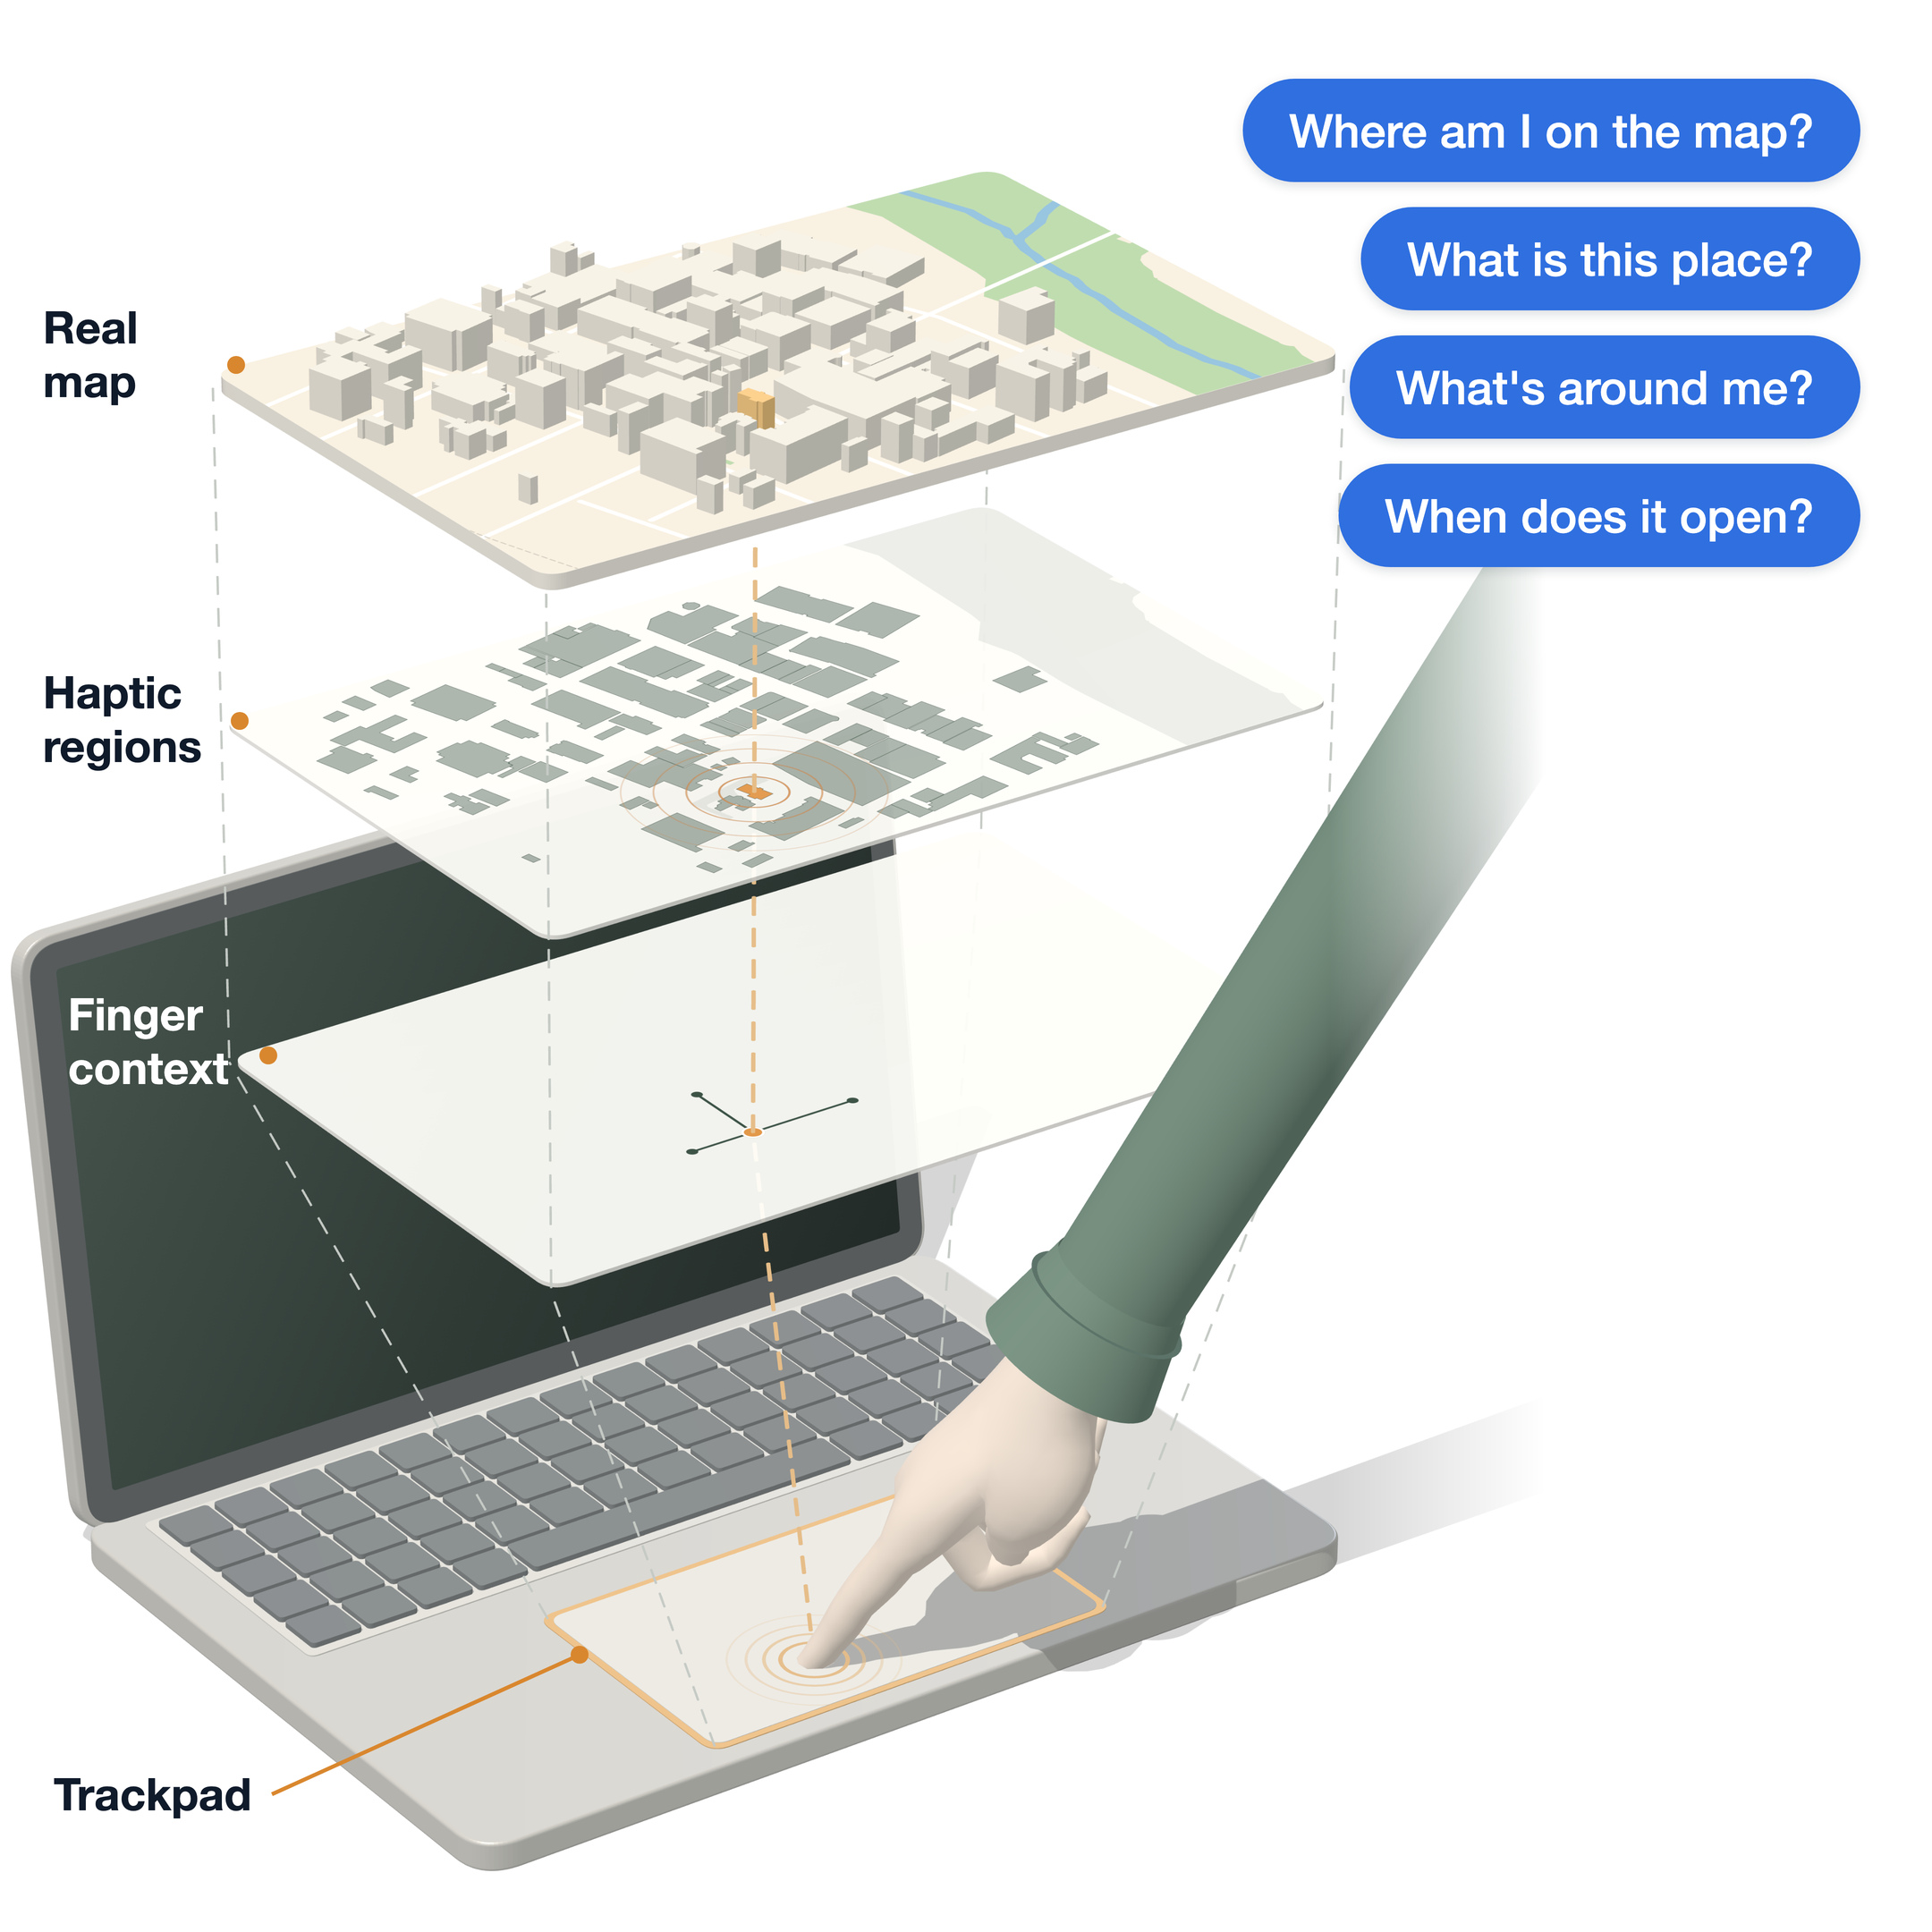
TouchingSpace: Blind users explore a map by touch and ask a voice agent about the place under their finger. We built it with a blind co-designer and tested it in person with 14 blind and low-vision adults.
This project aims to apply neuro-symbolic approach to instruct the COT process of LLMs for better verifiability and faithfulness/trustworthiness
October 2025 – Present
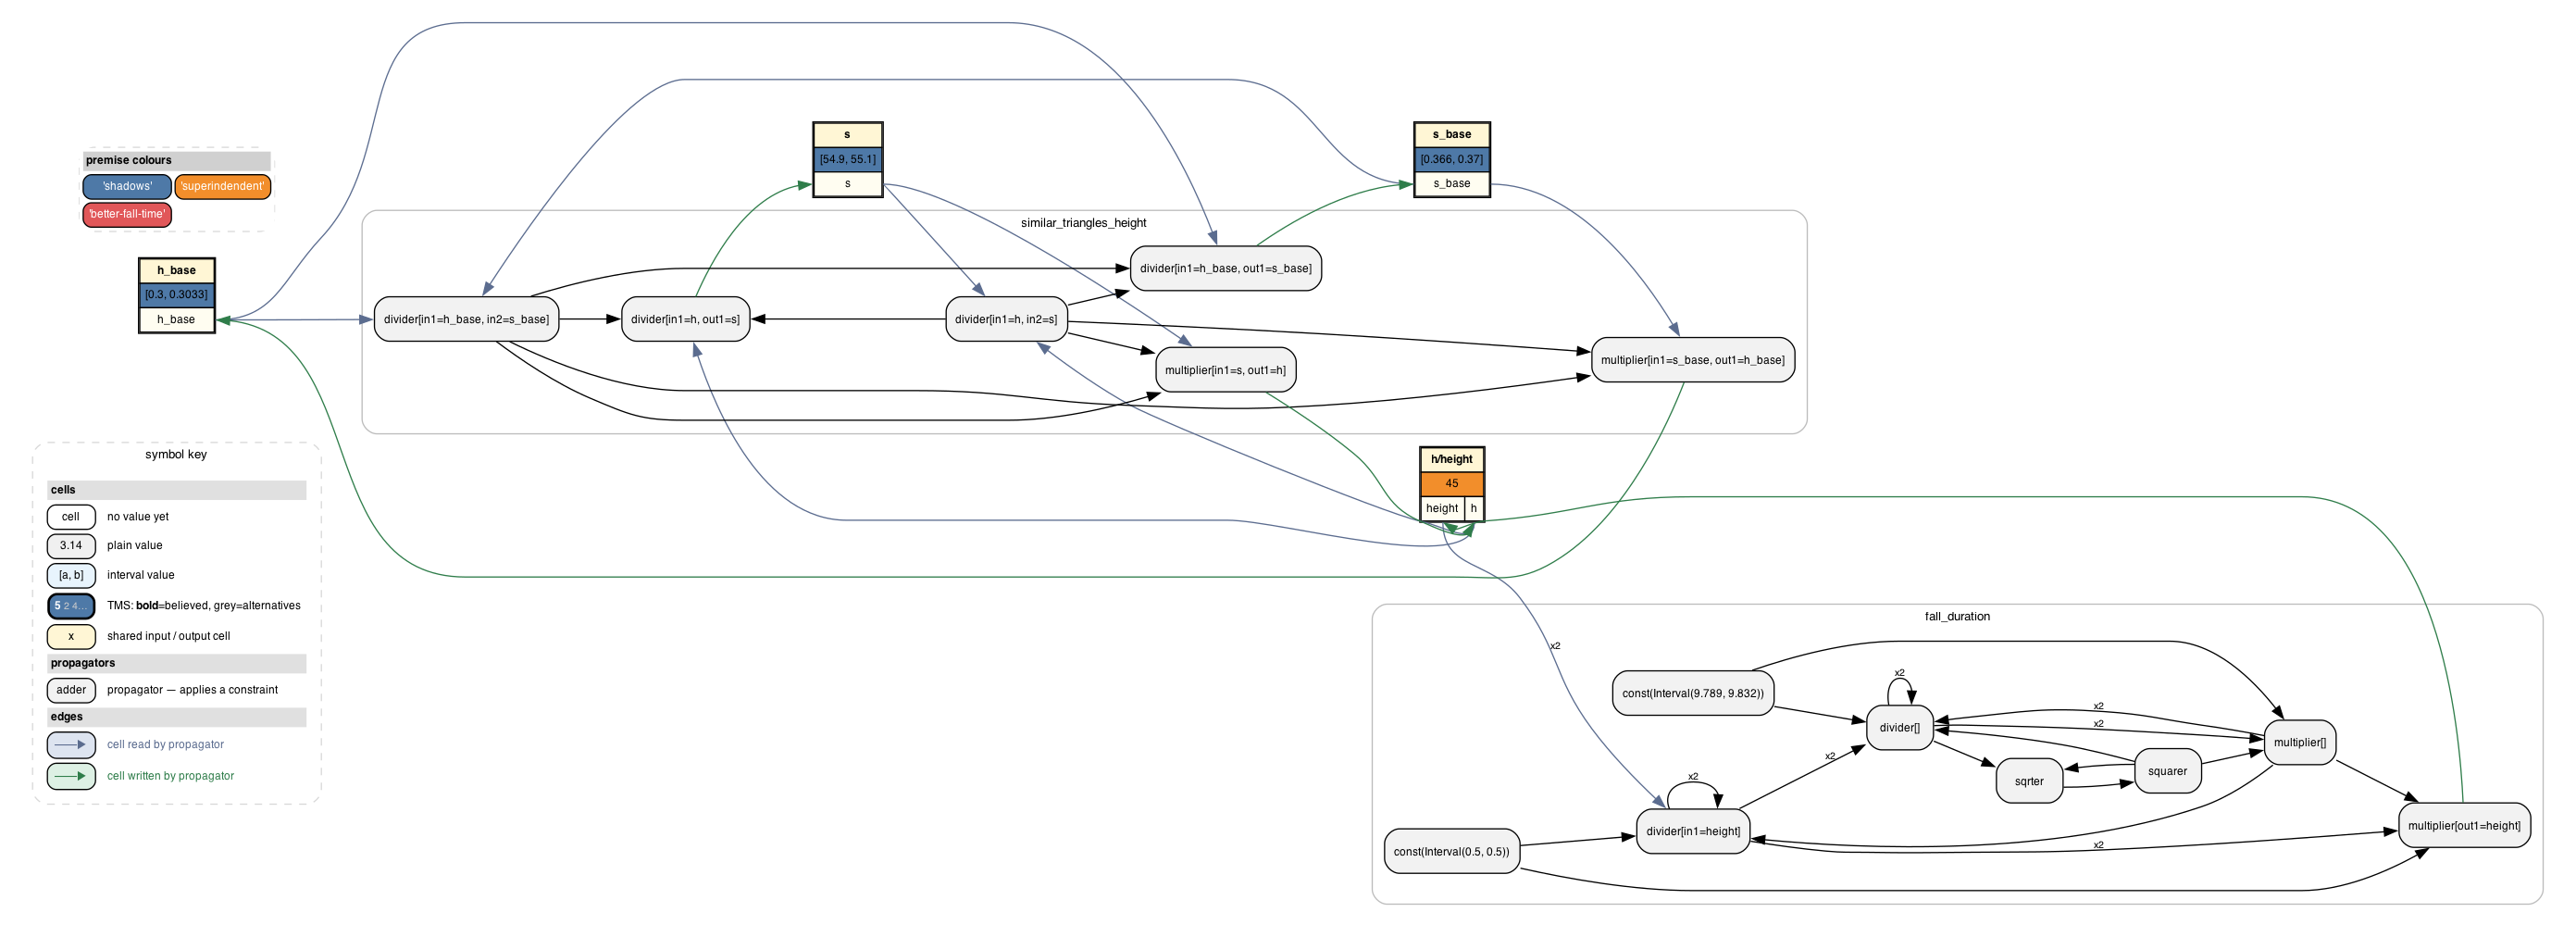
Propagators are a constraint-based programming model which we use to diagnose, understand, and monitor complex systems
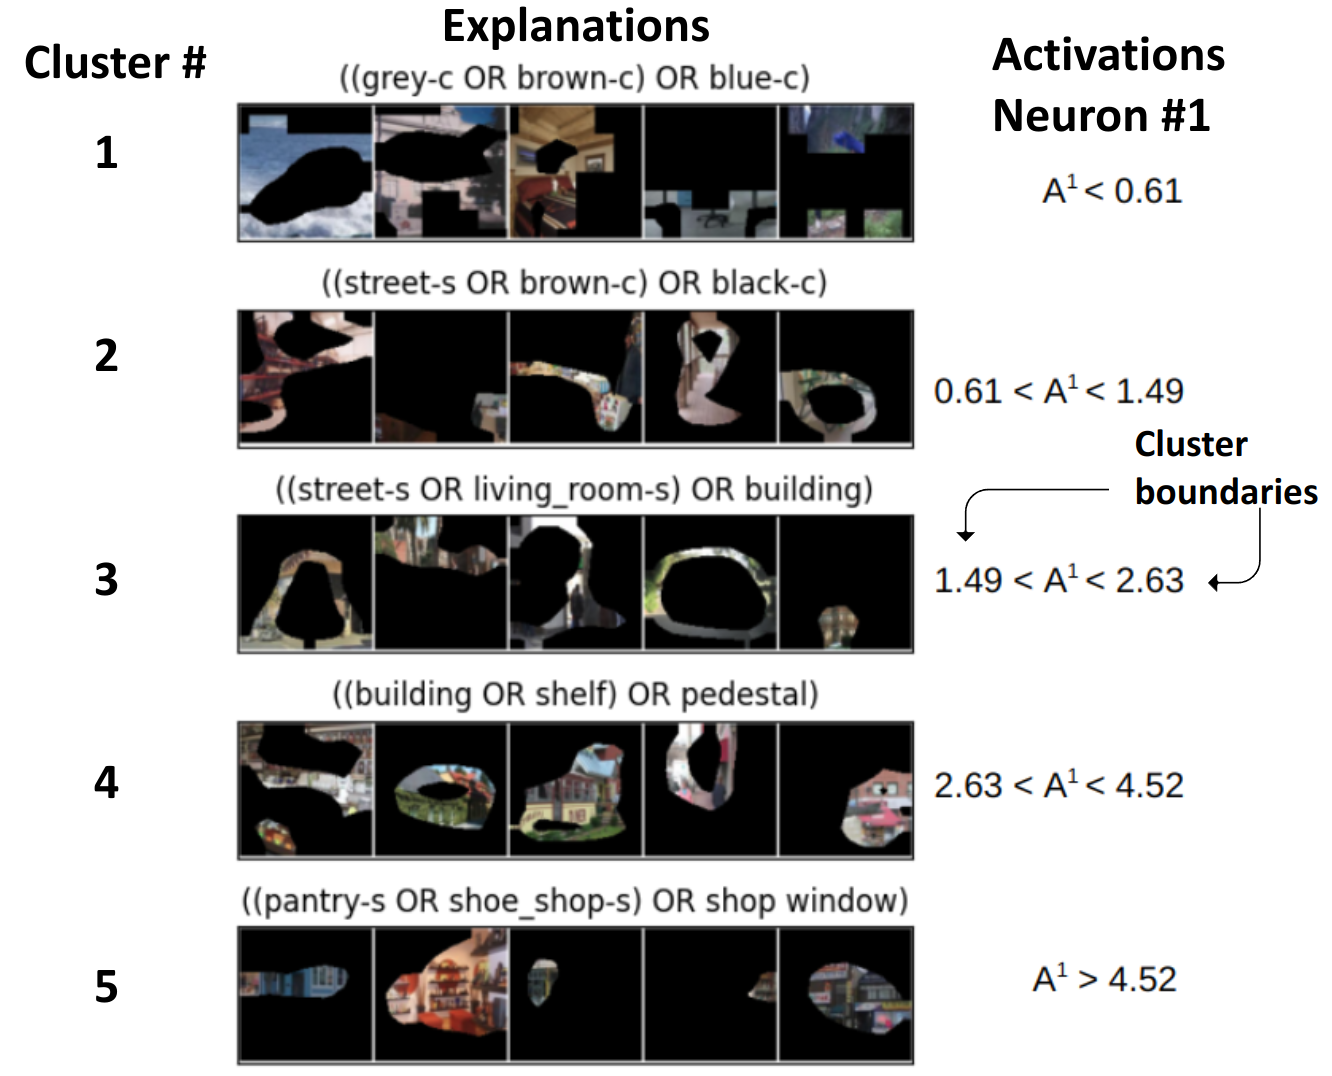
We explain what neurons learn using logical combinations of visual concepts, developing richer explanations across activation levels, open-vocabulary concepts, and algorithms with guaranteed optimality.
January 2025 – Present
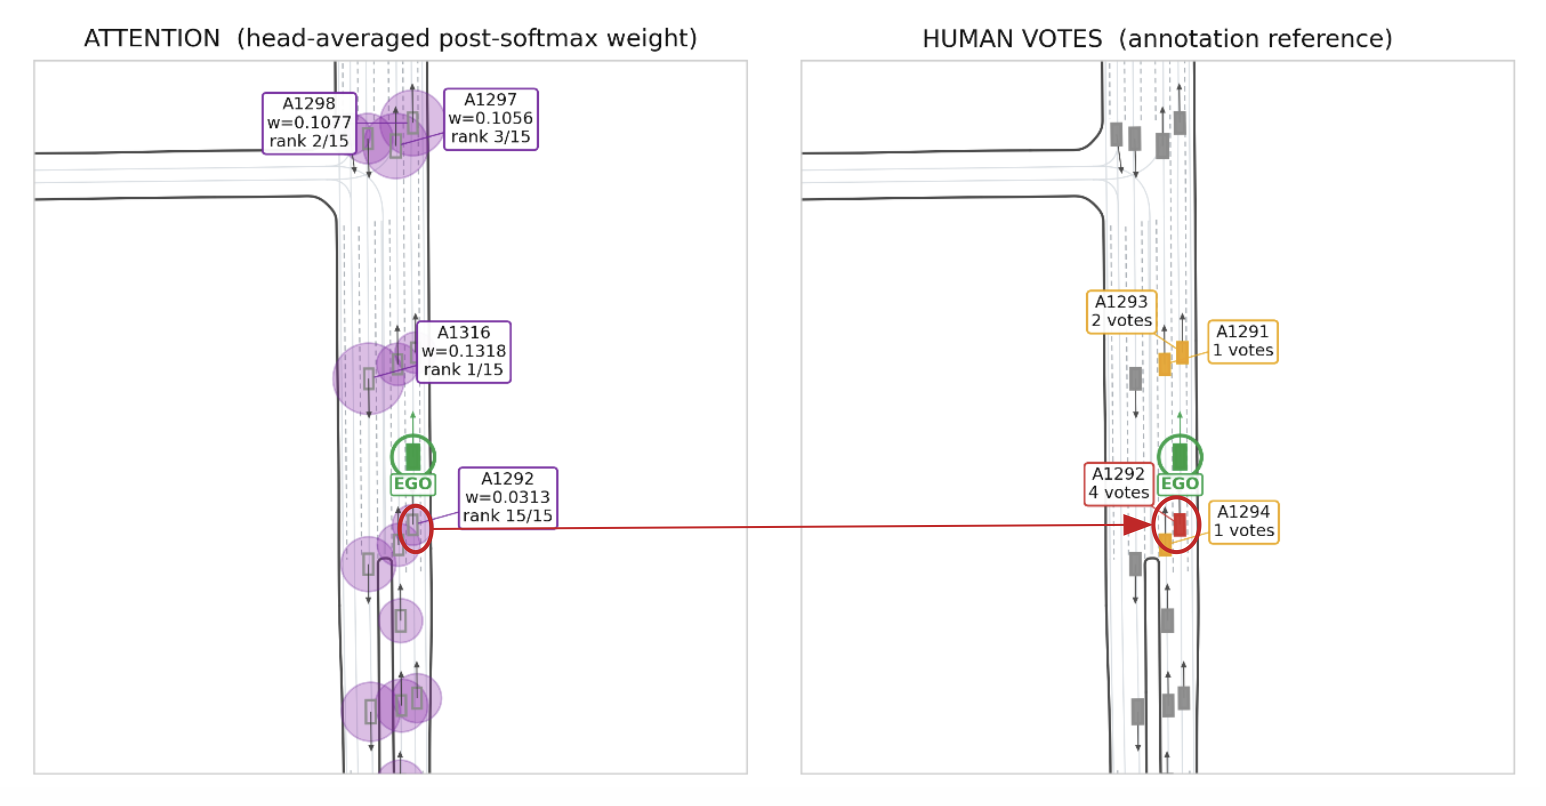
Understanding how autonomous vehicles reason about causality.
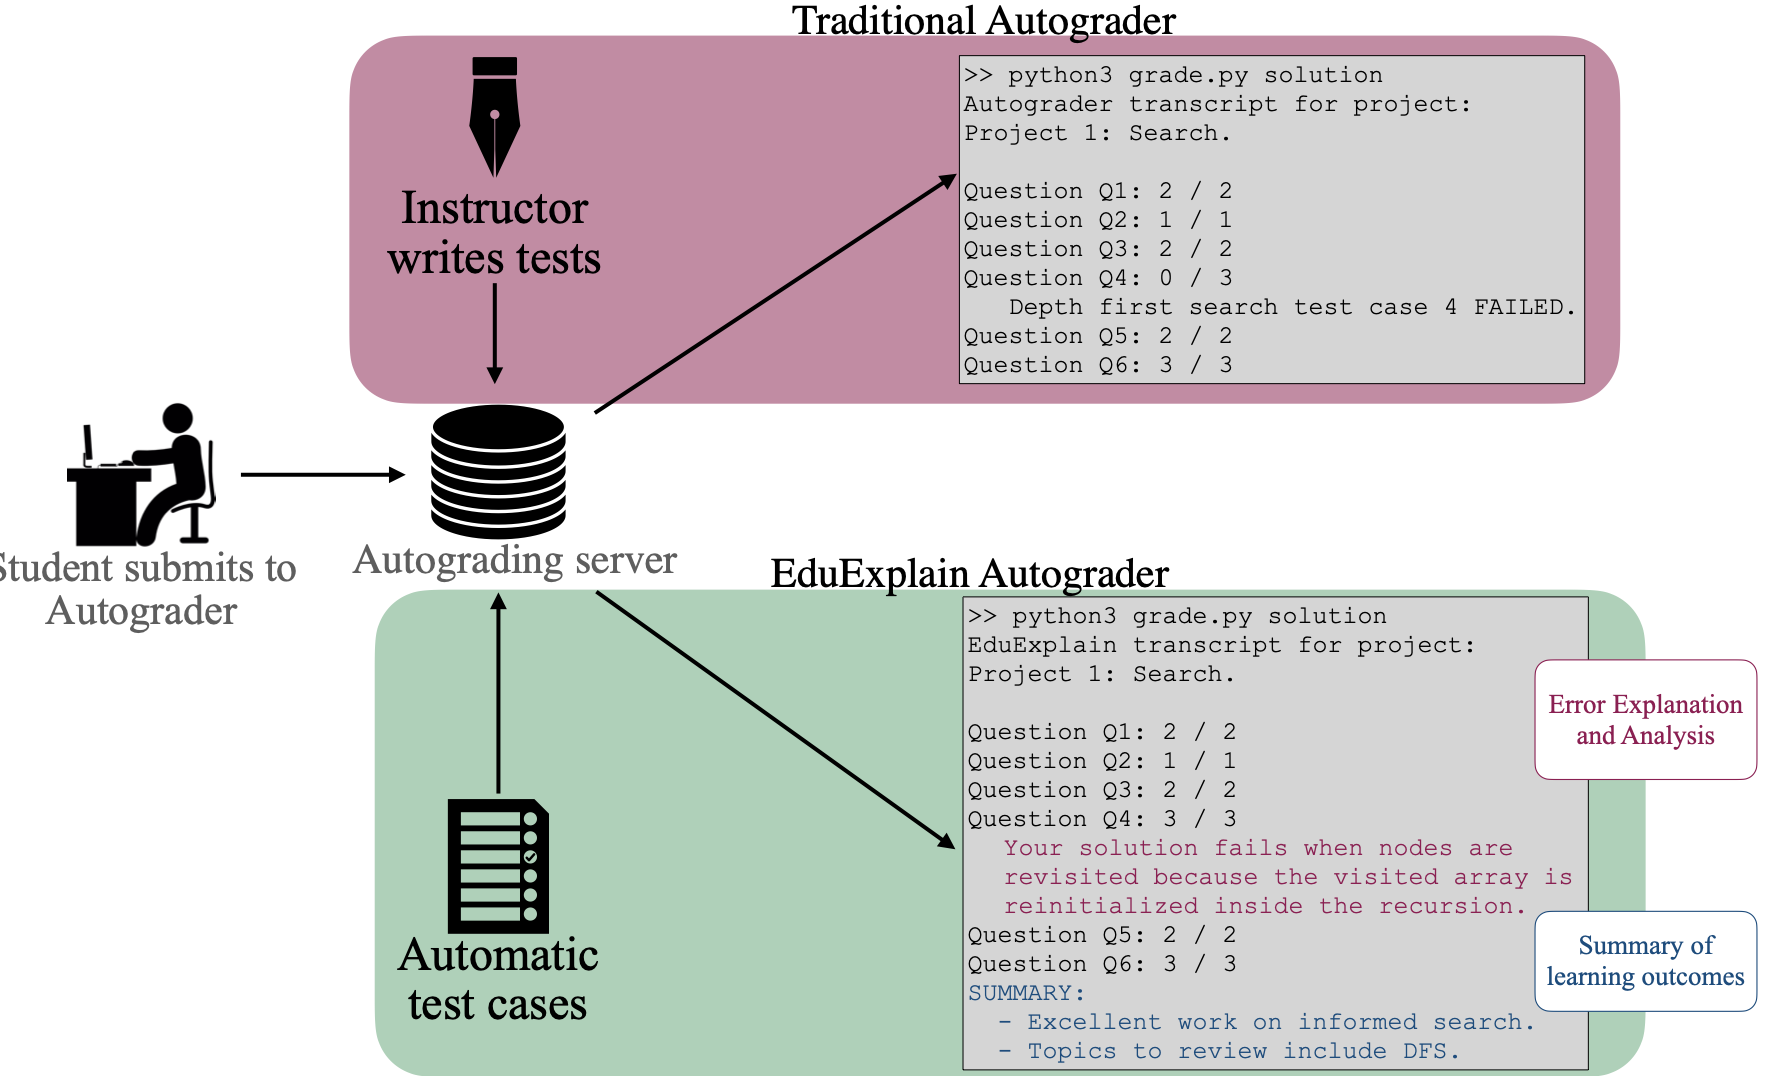
June 2023 – Present
A project to make automated assessment tools or autograders more explainable.
A collective advancing ethical AI through interdisciplinary collaboration, undergraduate mentorship, and justice-oriented co-creation of knowledge.
Developing interpretable reinforcement learning algorithms that transfer knowledge to new and unfamiliar environments.
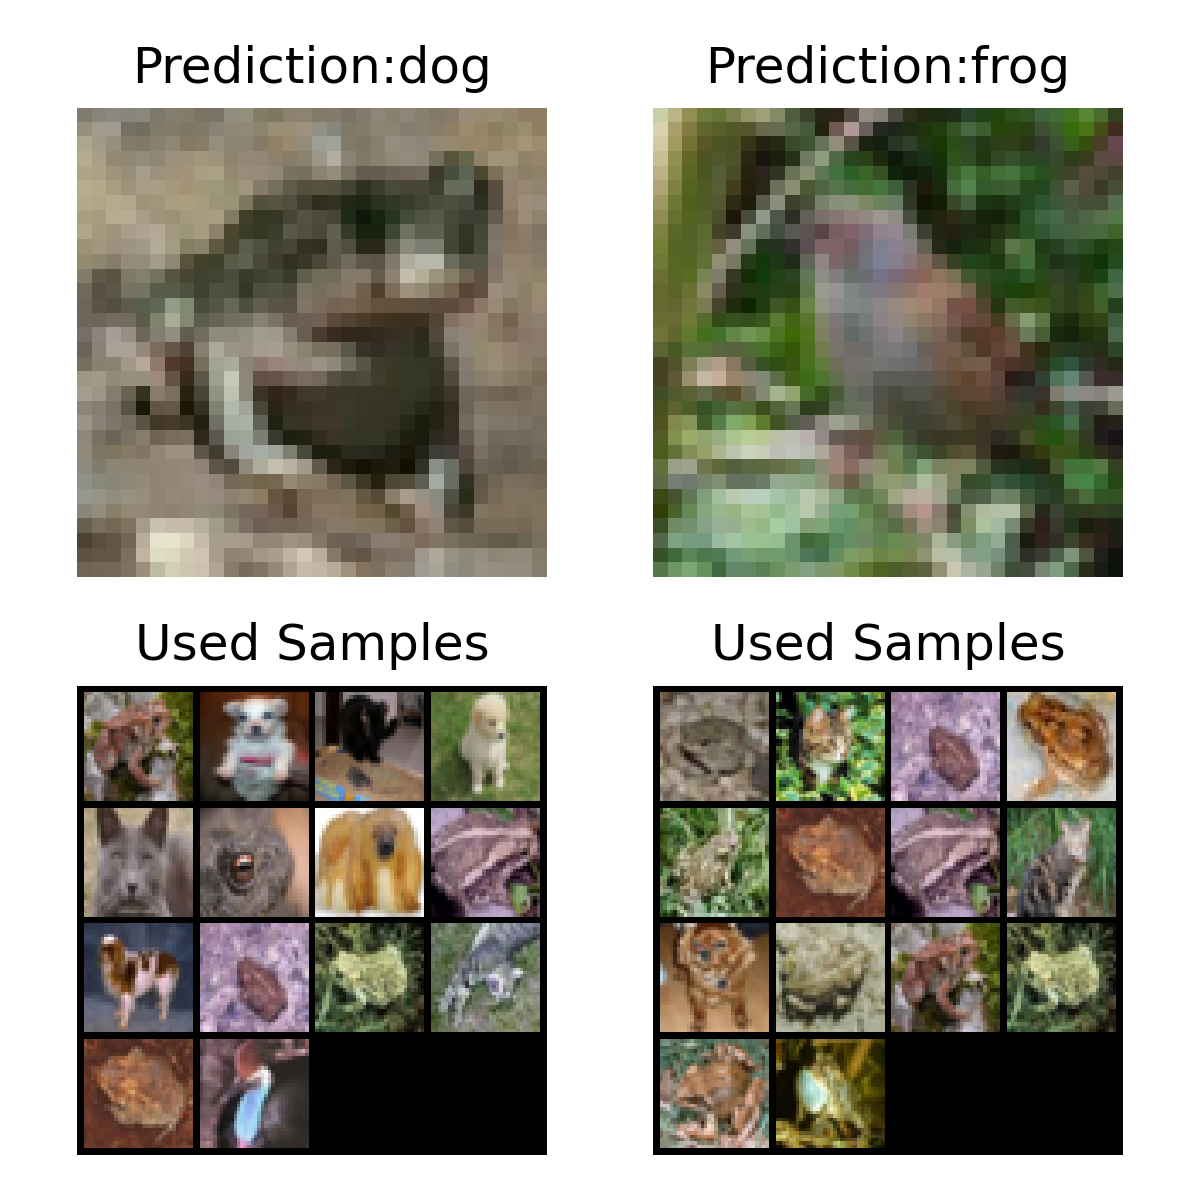
Inherently interpretable neural networks whose explanations influence predictions and reveal model reasoning, with a focus on computer vision, novel settings, architectures, and training methods.
Building a custom, open-source notetaker for our lab.
Turning handwritten notes into searchable text.
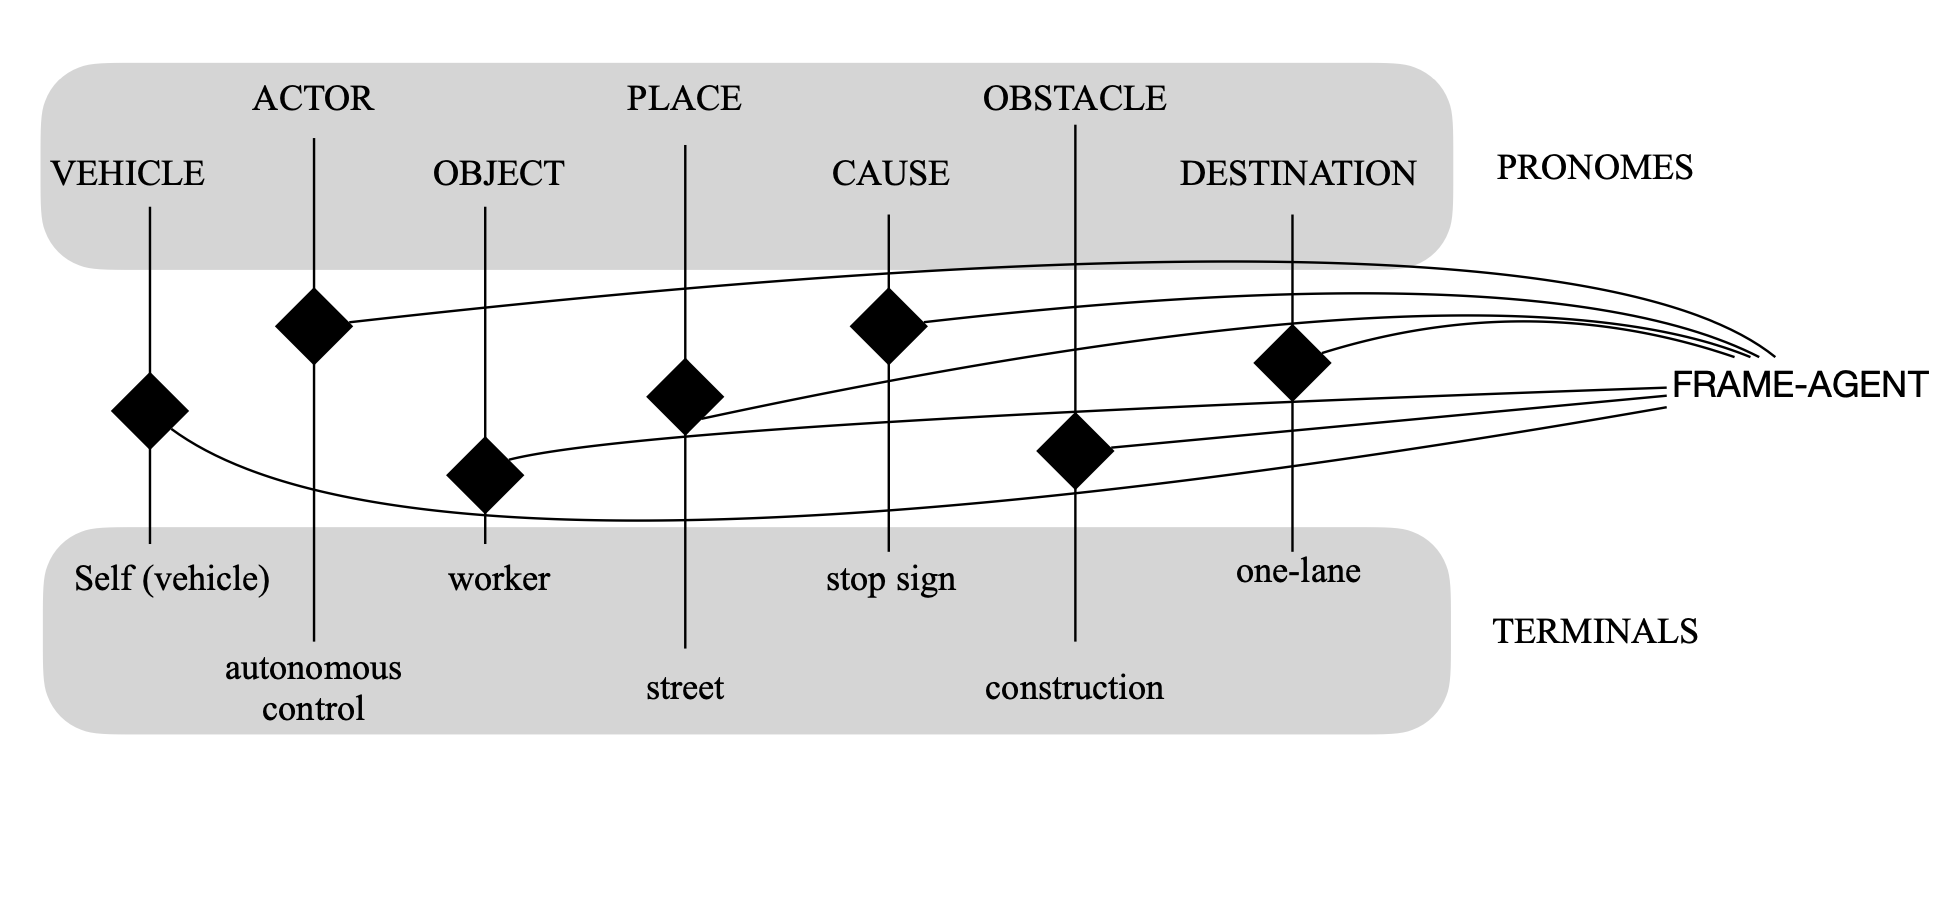
Translate autonomous system logs into a common, symbolic frame-based representation
Exploring autonomous vehicle path planning with algorithms such as D* and D* Lite.
Competing in open autonomous vehicle research challenges using open datasets, spanning Waymo, LiDAR, synthetic data, and vision-language-action models.
Exploring ethical decision-making in autonomous vehicles, including dilemmas such as the trolley problem.
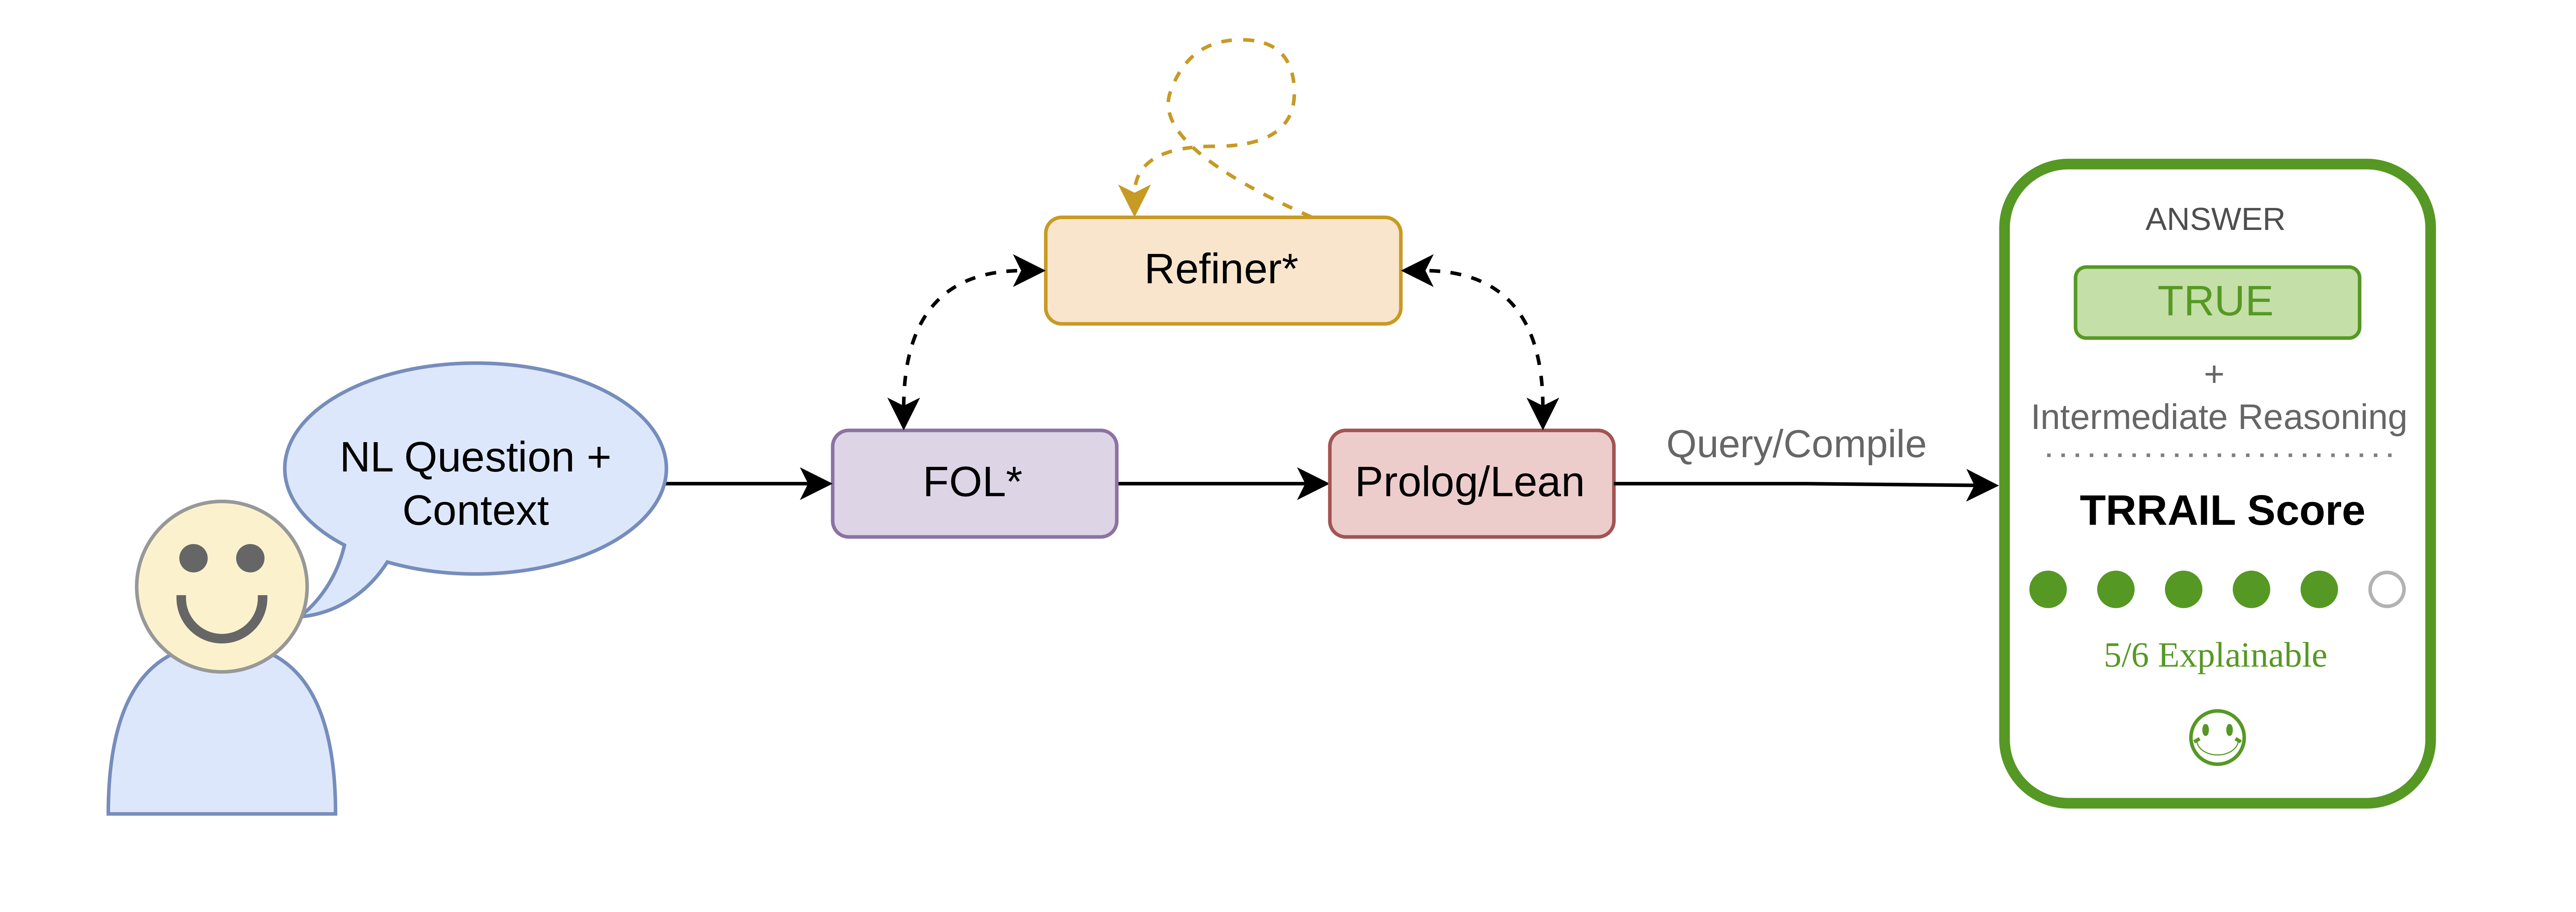
Reducing LLM hallucinations through neuro-symbolic reasoning and abductive learning for natural-language-to-Prolog translation.